Объем 207 страниц
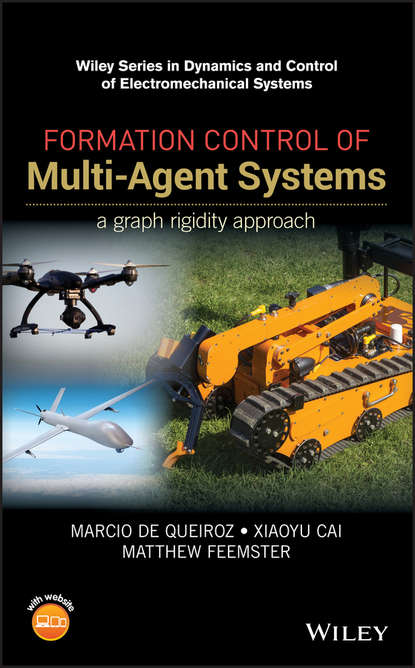
Formation Control of Multi-Agent Systems. A Graph Rigidity Approach
Начислим +508
Покупайте книги и получайте бонусы в Литрес, Читай-городе и Буквоеде.
Участвовать в бонусной программеО книге
Formation Control of Multi-Agent Systems: A Graph Rigidity Approach Marcio de Queiroz, Louisiana State University, USA Xiaoyu Cai, FARO Technologies, USA Matthew Feemster, U.S. Naval Academy, USA A comprehensive guide to formation control of multi-agent systems using rigid graph theory This book is the first to provide a comprehensive and unified treatment of the subject of graph rigidity-based formation control of multi-agent systems. Such systems are relevant to a variety of emerging engineering applications, including unmanned robotic vehicles and mobile sensor networks. Graph theory, and rigid graphs in particular, provides a natural tool for describing the multi-agent formation shape as well as the inter-agent sensing, communication, and control topology. Beginning with an introduction to rigid graph theory, the contents of the book are organized by the agent dynamic model (single integrator, double integrator, and mechanical dynamics) and by the type of formation problem (formation acquisition, formation manoeuvring, and target interception). The book presents the material in ascending level of difficulty and in a self-contained manner; thus, facilitating reader understanding. Key features: Uses the concept of graph rigidity as the basis for describing the multi-agent formation geometry and solving formation control problems. Considers different agent models and formation control problems. Control designs throughout the book progressively build upon each other. Provides a primer on rigid graph theory. Combines theory, computer simulations, and experimental results. Formation Control of Multi-Agent Systems: A Graph Rigidity Approach is targeted at researchers and graduate students in the areas of control systems and robotics. Prerequisite knowledge includes linear algebra, matrix theory, control systems, and nonlinear systems.